Unified world simulation of Lagrangian particle dynamics via Transformer.
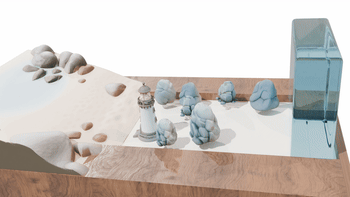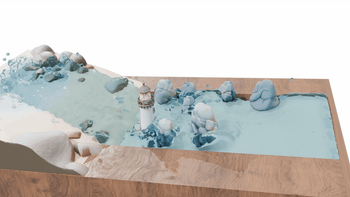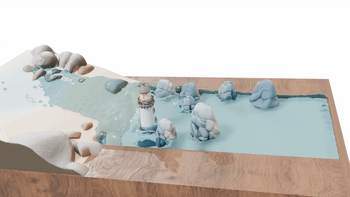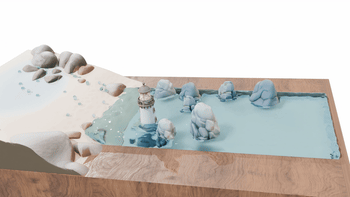
SIGGRAPH Asia 2026
WorldParticle
Unified world simulation of Lagrangian particle dynamics via Transformer.
The playground
Interactive experiments and a closer look at my research.
Drag to rotate. Change the winding. Find your own knot.
A visual experiment in geometry.Your browser could not start the 3D experiment. The research demos below are still available.
Results from the projects below, in motion. Open a preview to play, pause, and explore.
Unified world simulation of Lagrangian particle dynamics via Transformer.
SIGGRAPH Asia 2026
Unified world simulation of Lagrangian particle dynamics via Transformer.
Physically valid biomolecular interaction modeling with differentiable projection.
ICLR 2026
Physically valid biomolecular interaction modeling with differentiable projection.
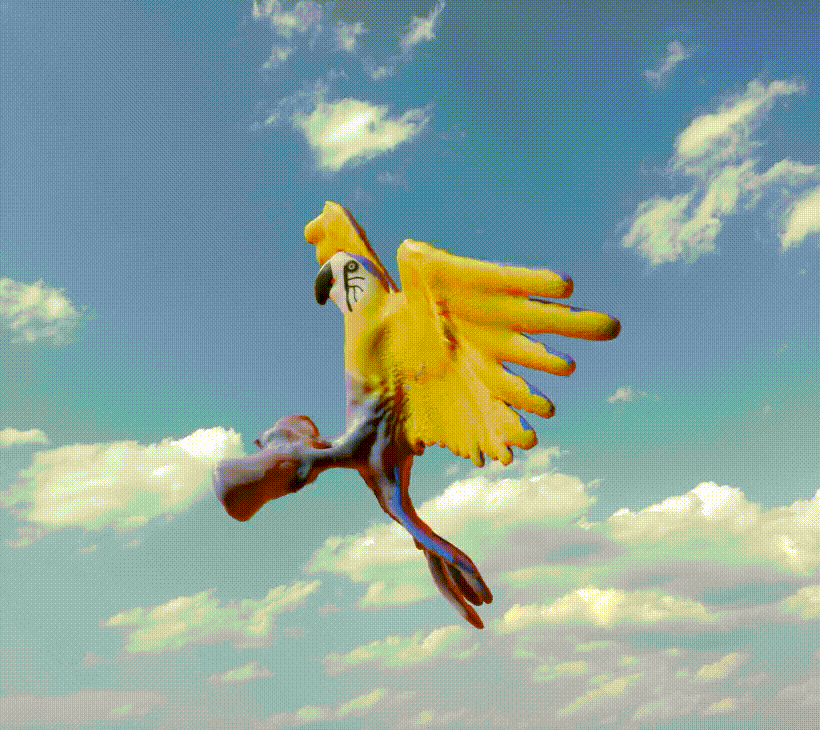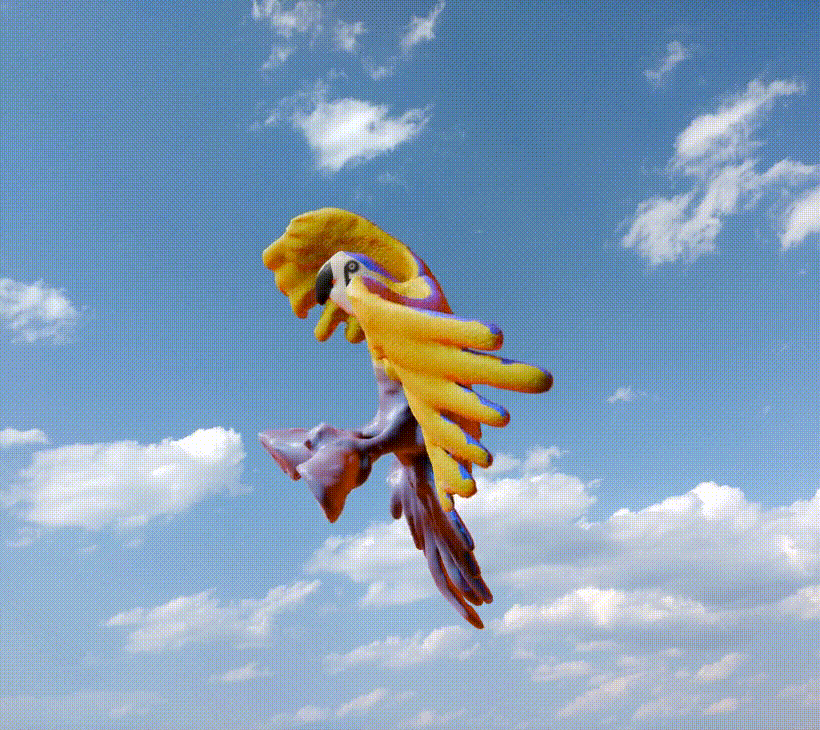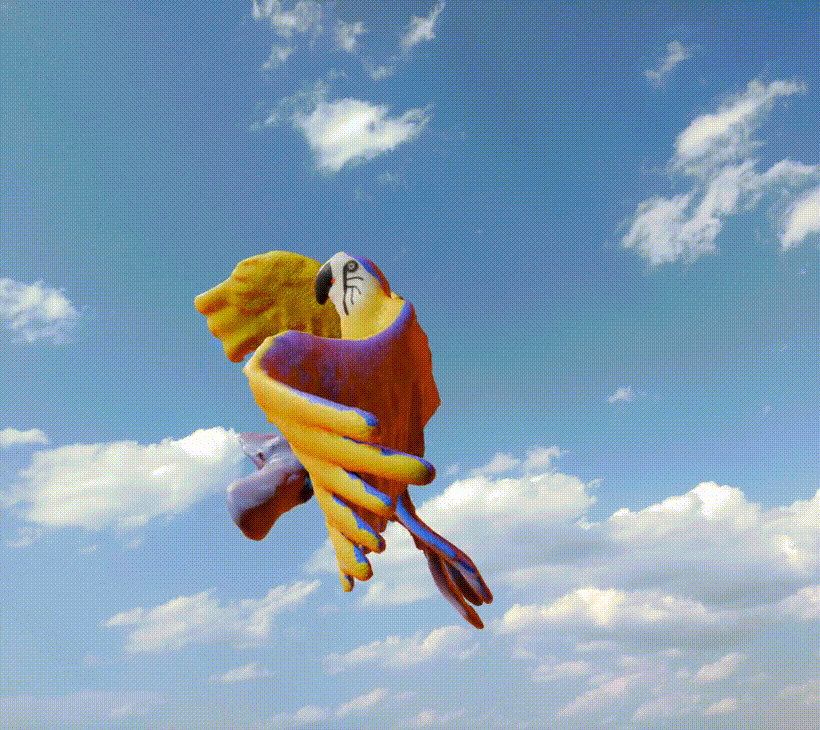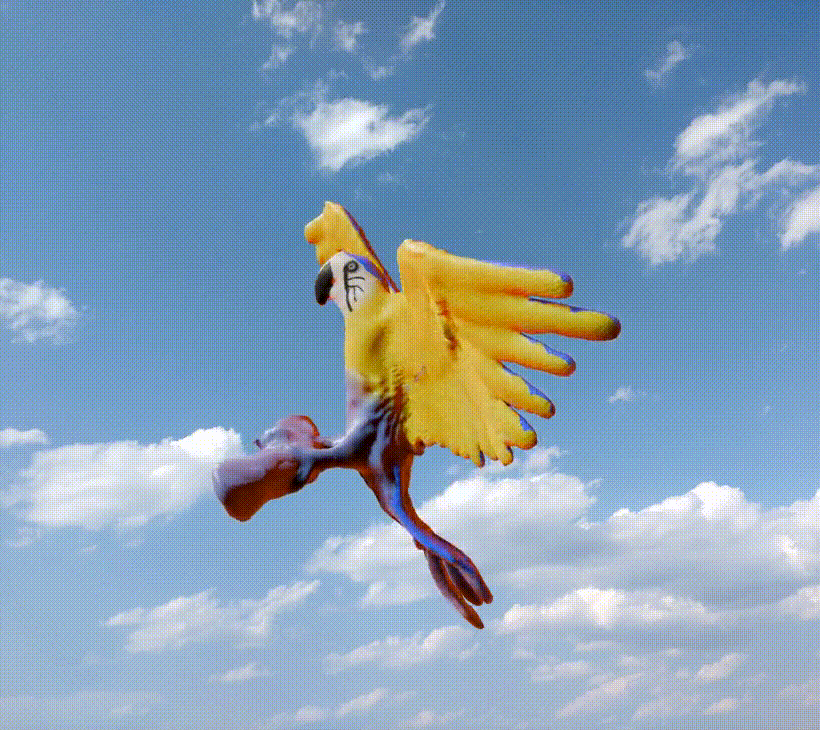
Equation-free cyclic animation via Koopman surrogates.
SCA 2026
Equation-free cyclic animation via Koopman surrogates.
Fast fluid simulation with an online temporally-aware reduced basis.
SIGGRAPH 2025
Fast fluid simulation with an online temporally-aware reduced basis.
Registered volumetric protein geometry for ligand-binding pocket classification.
Preprint · 2026
Registered volumetric protein geometry for ligand-binding pocket classification.
Open-boundary field solves, demonstrated in a ferrofluid simulation.
SIGGRAPH Asia 2026
Open-boundary field solves, demonstrated in a ferrofluid simulation.
Verification-guided agentic construction of physical worlds.
Preprint · 2026
Verification-guided agentic construction of physical worlds.
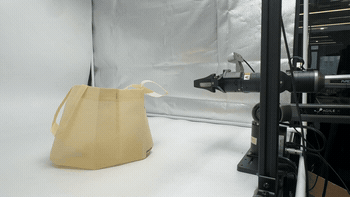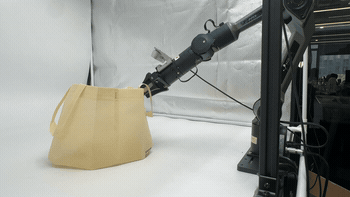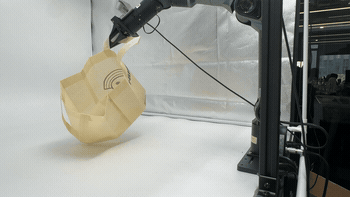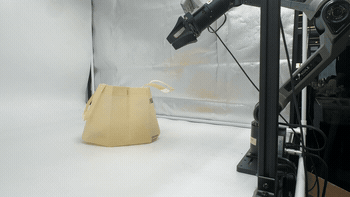
A contact-centric world model for scalable robot learning.
Preprint · 2026
A contact-centric world model for scalable robot learning.